At CPSquare, we conduct research on the problems that keep autonomous systems from quite making it out of the lab: environments that refuse to cooperate, models that are a little wrong, teammates that drop out, sensors that lie. Our projects span autonomous vehicles, aerial drones, and robot manipulators, and they tend to pull together threads from control theory, motion planning, perception, and learning into what's now being called Physical AI. The three directions below describe where we focus most.
We are consistently seeking ambitious graduate and undergraduate students interested in cyber-physical systems and robotics. If you're motivated by addressing fundamental challenges for autonomous systems and are considering theoretical/experimental research collaborations, feel free to contact sfarzan@calpoly.edu.
1. Agricultural Robotics for Efficient and Sustainable Farming
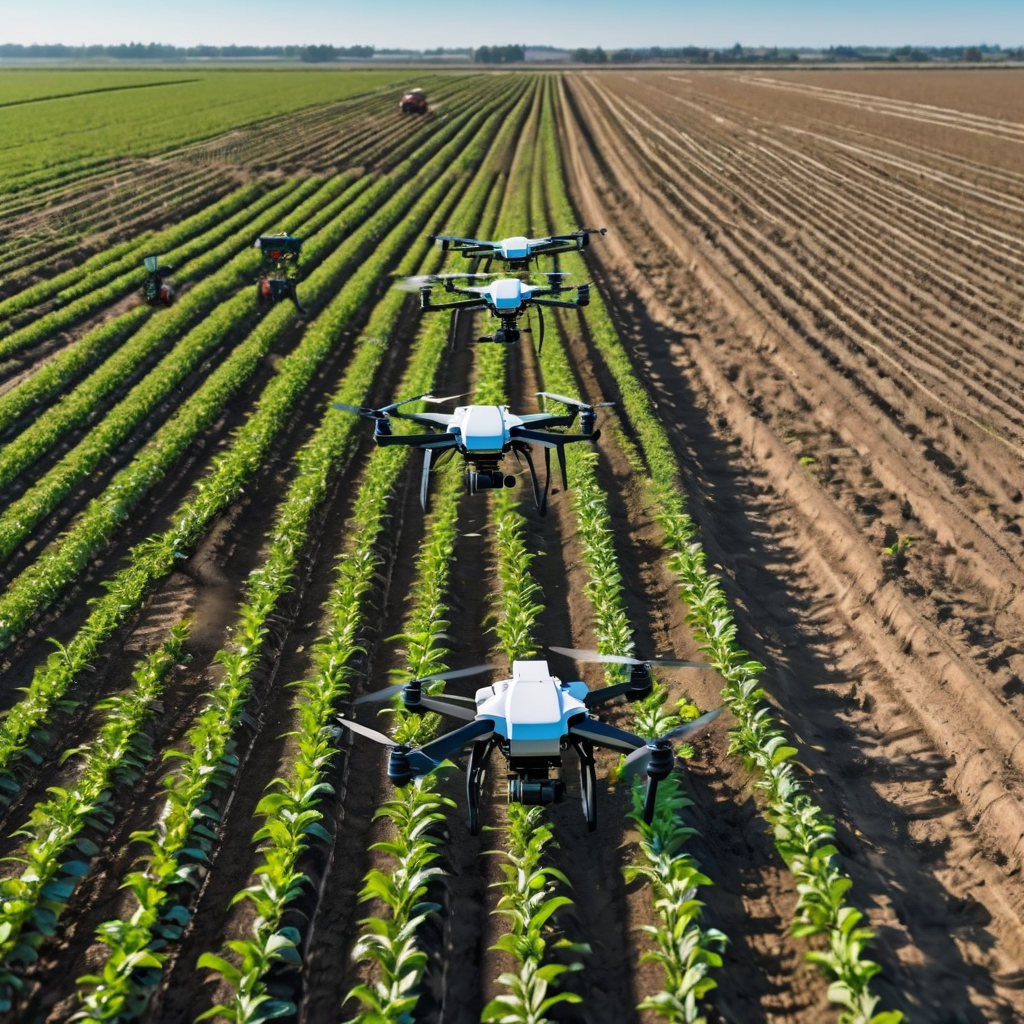
Agricultural robotics is a major focus of our lab. Farms are one of the hardest environments to automate: unstructured, ever-changing, weather-beaten, and unforgiving, which is exactly what makes them compelling. Working in vineyards and other specialty crop systems, with support from the USDA and CDFA, we bring together motion planning, control, computer vision, and learned perception to take robots from the lab into the field.
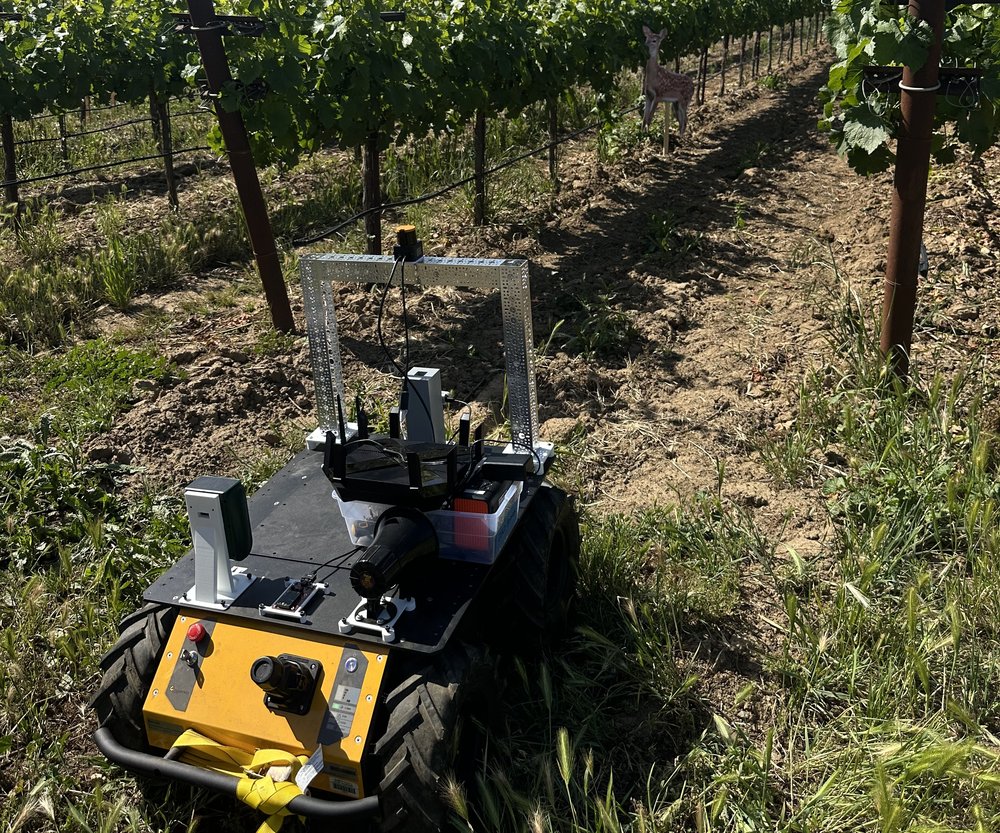
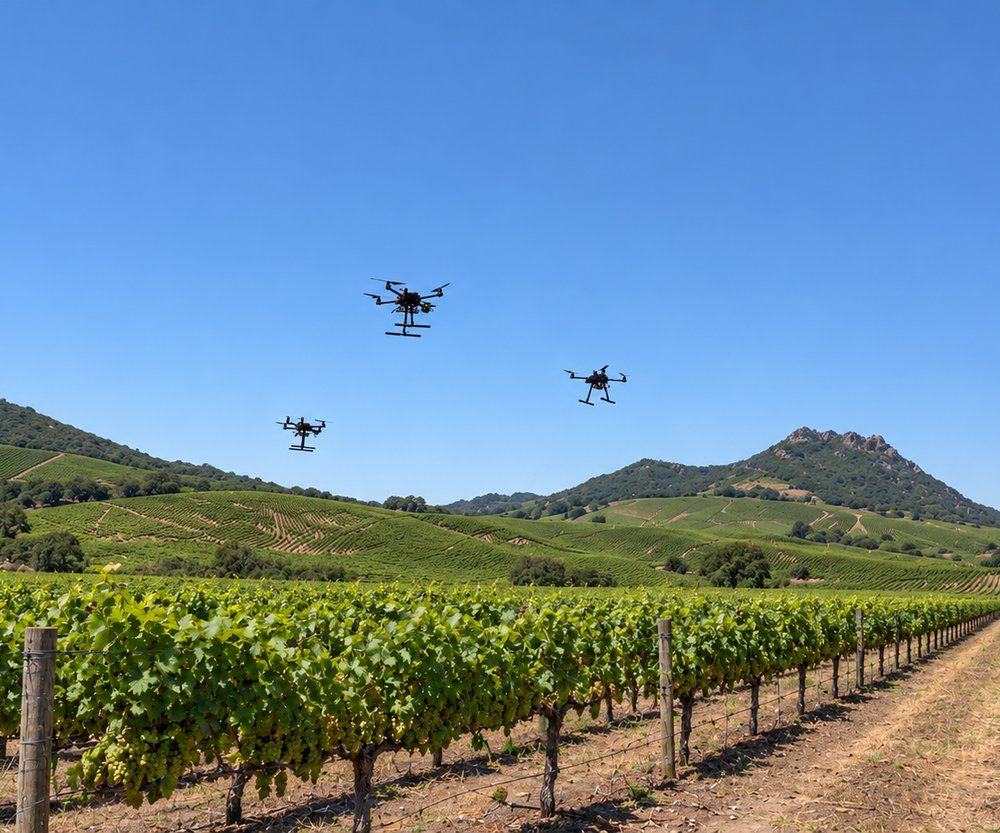
Using Physical AI methods that tightly couple perception, learning, and control on real robots, our current work addresses robust localization and state estimation and autonomous in-row navigation for ground robots, where dense canopies, uneven terrain, and seasonal change degrade perception; multi-robot formation control for coordinated field operations; autonomous harvesting through perception-guided manipulation of delicate crops such as table grapes; multi-UAV swarm monitoring for persistent crop surveillance across large areas; and UAV-based avian pest deterrence to reduce bird damage to crops. The long-term aim is to ease the labor burden and environmental footprint of producing food, while working in settings that continually push the limits of what our algorithms can do.
2. Robust and Safe Control and Physical-AI for Cyber-Physical Systems
This is the foundation for much of our work. We develop planning and control methods that let autonomous agents (ground vehicles, aerial drones, mobile manipulators) operate safely and predictably, either alone or as part of a coordinated team. Real systems have to contend with sensor noise, disturbances, unmodeled dynamics, degraded teammates, and dropped communication, so we lean on adaptive and robust control, control barrier functions, and optimization-based planning to build methods that degrade gracefully rather than catastrophically. The problems that pull us in most right now are highway platoons, aerial swarms, distributed estimation across sensor networks, and fault-tolerant coordination in heterogeneous fleets.
3. Vision-Guided Planning and Manipulation for Industrial Automation
A lot of what holds robots back in manufacturing and logistics isn't mechanical; it's the gap between what the robot perceives and what it can confidently act on. Our work in this area tries to close that gap by tightly coupling perception with motion planning and control. We're drawn to visual servoing for precise manipulation, grasp planning under partial or noisy observations, and handling the deformable, variable objects (stacks of envelopes, fruit, mixed parcels) that historically required a human touch. The goal is flexible automation that holds up outside the carefully controlled environments where traditional industrial robots have always lived.